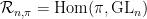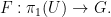In this blog post, I want to explain a way in which I like to motivate Lie groupoids via the theorem on the existence and uniqueness of solutions to ordinary differential equations. The basic idea is that in trying to do away with the choices – the initial time and the initial conditions – we’re naturally led to consider a ‘universal fundamental solution’. This is a matrix function depending on two parameters, the initial and final times, and it must satisfy a homomorphism-type condition. In order to axiomatize this condition, we are automatically led to the definition of a Lie groupoid. Once this has been absorbed, we can then rephrase the existence and uniqueness theorem as a correspondence between ODEs and representations of the pair groupoid of the real line. This is a special case of Lie’s second theorem for Lie groupoids.
Continue reading “Lie groupoids and differential equations”List of posts
How to build the Stasheff Associahedron out of a trefoil knot
The Stasheff Associahedra are a family of polytopes that seem to be ubiquitous, but in particular are strongly linked to associativity. Here are the first few:
The vertices of the -dimensional associahedron
are in bijection with bracketings of the word
, or equivalently, with the set of planar binary trees with
leaves. For example, there is a single way of bracketing the word
, and therefore,
is a single point. On the other hand, there are two ways of bracketing the word
. They are
and
. Correspondingly,
is an interval. Here are the first three associahedra with the labelling of their vertices by trees.
Loday pointed out a mysterious relationship between the trefoil knot and the -dimensional associahedron
. Namely, he showed that there is natural way in which the trefoil knot can be drawn on the surface of
. Here is a picture:
The Volume of an Even Dimensional Ball
What is the volume of a ball of dimension
and radius
? This ball is the following subset of
:
and we measure the volume using the standard Euclidean measure.
If you only need the answer for even dimensions, here’s an easy way to remember: define to be the sum of the volumes of balls of radius
over all of the even dimensions:
.
Remarkably, the formula for this function turns out to be . This is easy to remember since it’s the exponential of the volume (i.e. the area) of a disc. Then, you can read off the volumes
as the terms in the Taylor expansion of
. Explicitly:
A nice, and immediate, corollary is that the derivative of , with respect to the radius
, gives you the sum of the volumes of all of the odd-dimensional spheres:
By looking at the coefficients of the Taylor expansion, we can conclude that the volume of the unit sphere of dimension is
.
There’s a lot more to say about the volumes of balls and spheres, and if you’re interested, the Wikipedia page is a good place to start.
Okay, but why is the formula for true? And what’s special about even dimensions? That’s what I want to explain in this post.
How does a Lie algebra encode a space? (Part 2)
In my last post, I told you how to encode the zero locus of a polynomial function in terms of an
-algebra structure on
, where
lies in degree
and
lies in degree
. Namely, we simply defined the
ary bracket on
to be the
Taylor coefficient of
This gave us one of the simplest examples of a derived manifold: the derived vanishing locus of
It also illustrated a simple ‘principle’ of derived algebraic geometry: if the equations defining a space are not independent, then don’t impose them. Instead treat the equations as geometric spaces in their own right. This is useful in part because it allows us to avoid dealing directly with the space defined by the equations, which can often be quite pathological.
In this post, I want to discuss the other side of the story: quotients. What if we are trying to define a space by imposing an equivalence relation that fails to be independent in some way? Again the result can be quite pathological and the solution to this problem is, once again, to do nothing: just don’t take the quotient and treat the equivalence relation as a geometric space in its own right. This will lead us to Lie groupoids and then to stacks, which are Lie groupoids up to Morita equivalence. But what I’m really aiming towards is the infinitesimal counterpart to a Lie groupoid, which is called a Lie algebroid. After reviewing the definition I will explain that, by taking the Taylor coefficients of the structure maps, a Lie algebroid can locally be encoded by an -algebra, this time concentrated in degrees
and
. This
-algebra, considered up to quasi-isomorphisms, encodes the formal quotient stack associated to the Lie algebroid. This post will be a little longer and a bit less concrete than the last one, but I still hope that it will help demystify both stacks and
-algebras.
How does a Lie algebra encode a space? (Part 1)
A fundamental principle of derived deformation theory is that a formal “space” (i.e. formal moduli problem) can be encoded by a differential graded Lie algebra, or more generally, an -algebra. This is usually attributed to a number of famous mathematicians, such as Quillen, Deligne, Drinfeld, Goldman, Millson, Feigin, Manetti, and Kontsevich. More recently, a formalization of this principle was independently obtained by Lurie and by Pridham.
In this post, I want to discuss a simple example of this: how to encode the ‘derived’ vanishing-locus of a function using an -algebra. My goal is to show that, far from being a high-brow construction, this essentially boils down to the familiar Taylor series expansion. After explaining this fact, I will go through a number of concepts and constructions in the world of
-algebras and show how they can be translated into the setting of a function and its zero locus. Hopefully, this will help to demystify the notion of derived manifolds for myself and maybe for others. In a future post, I will discuss the ‘stacky’ version of this story: how to describe a Lie algebra action, or a Lie algebroid, in terms of an
-algebra. As usual, there might be some (hopefully minor) errors in what follows, so proceed with caution!
Characters, Brackets, and Skeins
The character varieties are a remarkable family of spaces that lie at the center of many different active strands of research of the past 30 or 40 years. The basic definition is actually quite simple. We start with a group , and consider the space of representations
.
This space is an algebraic variety, possibly with singularities, and there is an action of given by conjugation. We can think of this as a change of basis in the representation. The character variety is the quotient
.
There are a few things to note here. First, we can easily replace by any Lie group
in the definition, giving what we can call the
-character variety. Second, the group
is usually the fundamental group of a manifold
. In this case, the Riemann-Hilbert correspondence says that the character variety is (analytically) isomorphic to the moduli space of flat connections on
. Roughly, the flat connections are certain kinds of differential equations on the manifold, and by solving them we obtain monodromy representations of the fundamental group. These give the corresponding points of the character variety.
Arguably, the most interesting examples occur when the manifold has dimensions two or three. For example, in dimension two the character variety is a Poisson manifold, whereas, in dimension three, it is closely related to things like Chern-Simons theory and knot invariants. Recently, I’ve been trying to learn a bit more about the relations to low-dimensional topology: things like the Goldman-Turaev Lie bialgebra, string topology, and skein algebras. Below I’ll try to summarize a bit of what I’ve understood so far, along with some questions and confusion.
A ‘counterexample’ to Deligne’s construction
Let be a holomorphic line bundle over a complex manifold
. The total space of this bundle is a complex manifold in its own right, and it contains the smooth hypersurface
, which is embedded as the set of zero vectors. Let
denote the complement.
Let be a complex Lie group. In this post we will study principal
-bundles
that are equipped with connections
which are flat and have logarithmic singularities along
. Denote the category of these connections
. Given any connection
, we can restrict it to
, where it defines a non-singular flat connection. By the Riemann-Hilbert correspondence,
is equivalent to a homomorphism
In fact, we get a ‘restriction functor’
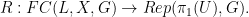
Question : Does every -representation of
come from an object of
?
When the group , Deligne’s construction answers this question in the affirmative. In a previous blog post, I explained this construction, as well as some of the required background on flat logarithmic connections. A key tool in this construction is the fact, explained in another blog post, that a set-theoretic logarithm determines canonical matrix logarithms. This fact about
is not shared by other groups, and hence Deligne’s construction does not extend. The purpose of this post is to give a counterexample to the Question when
.
In order to construct the counterexample, I will use a description of the category that I provided in my paper. This applies in the case that
is complex and reductive, but for this post, I will stick to the case of
.
Gugenheim’s Theorem
An absolutely central concept/tool in modern mathematics is that of (co)homology. In one of its earliest incarnations, the singular (co)homology of a topological space, it consists of a sequence of groups that measure the number of ‘holes’ in a space of various dimensions. This can take an inscrutable geometric shape, and boil it down to a more understandable sequence of groups.

One of the strengths, but often confusing aspects, of (co)homology is that it has a dizzying number of different definitions, which are often equivalent but in a highly non-obvious way.
Continue reading “Gugenheim’s Theorem”Deligne’s construction for extending connections.
In this post I will discuss a construction, due to Deligne, for extending a flat vector bundle to a flat logarithmic vector bundle. The setting of the construction is as follows: let be a smooth complex manifold, and let
be a divisor (i.e. a codimension 1 subvariety). Then given a branch of the logarithm
(it is in fact sufficient to choose a ‘set theoretical’ logarithm) Deligne’s construction gives a canonical way of extending a flat holomorphic vector bundle on the complement of
to a holomorphic vector bundle on
with a flat logarithmic connection having poles along
:
Theorem. Let be a holomorphic vector bundle with flat connection on
. There exists a unique extension
to all of
such that
has logarithmic singularities along
and the eigenvalues of the residue of
lie in the image of
.
Continue reading “Deligne’s construction for extending connections.”
Matrix Logarithms
Consider the exponential map for matrices , which can be defined by the formula
where is a square matrix. A matrix logarithm is defined to be a right-inverse to the exponential; that is to say, it is a function
such that
. It is a standard result of Lie theory that the exponential is a diffeomorphism in a neighbourhood of
in
, and hence there is a well-defined choice of logarithm in a neighbourhood of the identity in
. However, it is not at all clear that a logarithm can be globally defined, or that there is a unique way of doing so. This problem also shows up in the more simple case of the exponential for complex numbers. Indeed, there are several choices for the complex logarithm, and none of them are analytic (or even continuous) on all of
. However, it turns out that choosing a complex logarithm is enough to determine a unique choice of a matrix logarithm in any dimension. More precisely, we have the following:
Theorem. Consider the exponential sequence for complex numbers
and let be a set-theoretical splitting of this sequence, in other words, a (not-necessarily continuous) branch of the complex logarithm. Then for any positive integer
, there is a uniquely defined matrix logarithm
such that for every the eigenvalues of
lie in the image of